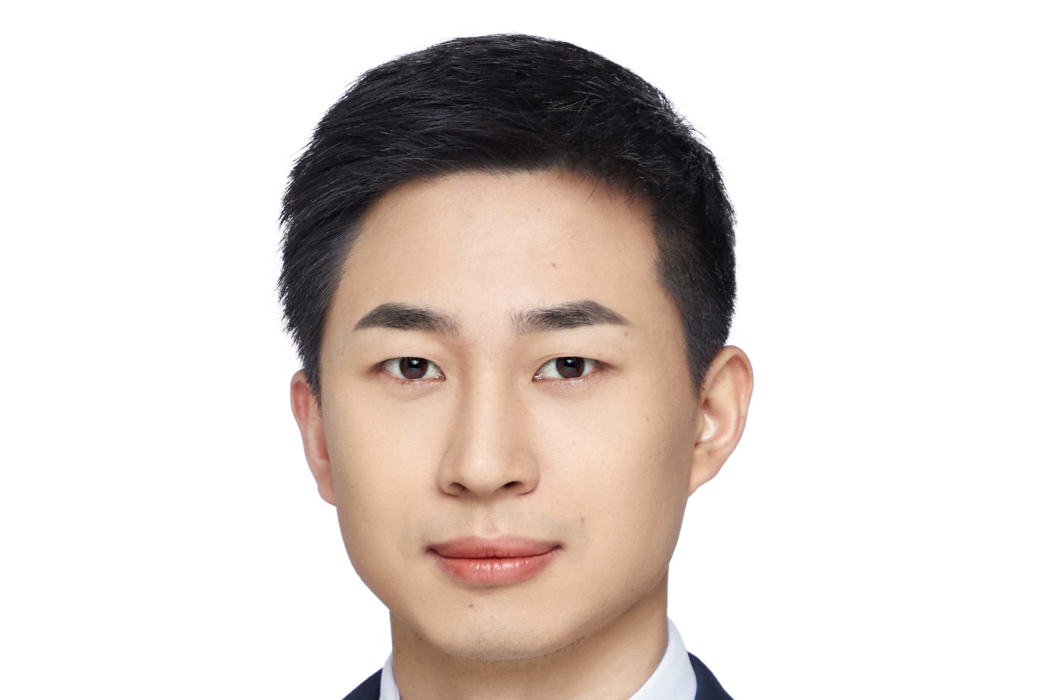
楊路,北京理工大學機械與車輛學院預聘助理教授/特別副研究員,碩士生導師
基本介紹
- 中文名:楊路
- 國籍:中國
- 職業:教師
研究方向,主要成就,所獲榮譽,社會任職,
研究方向
車輛是國民經濟的重要支柱產業,智慧型化是車輛技術的主要變革方向,車輛智慧型安全是科學技術進步面臨的重要課題。複雜道路交通環境下常存在駕駛人操控失誤、車輛突發故障、周車運動意圖不定及天氣與道路條件非理想等挑戰,加上人-車-路閉環系統非線性疊代放大,極易發生自車失穩和車車碰撞等惡性事故。複雜環境下閉環系統要素作用機理及行車風險規避是提升車輛運動安全性能亟待解決的關鍵科學問題,圍繞複雜道路交通環境下車輛智慧型駕駛,運用系統動力學、強化學習、預測控制及最最佳化方法等理論方法,開展人機系統動力學及車輛智慧型化協同決控研究。主要研究方向包括:
(1) 智慧型車輛人機系統動力學理論
(2) 車輛智慧型駕駛決策與控制技術
主要成就
聚焦車輛控制及智慧型化研究方向,近年來在IEEE Trans., ASME Trans., Nonlinear Dynamics等汽車及控制領域重要學術期刊及會議發表SCI/EI論文二十餘篇,Google Scholar學術引用一百四十餘次;獲授權國家發明專利九項。主持國家自然科學基金項目一項,以核心成員參與國家自然科學基金重大項目(課題)、重點項目等多項。研究成果曾獲遼寧省自然科學學術成果獎、第十八屆亞太智慧型交通論壇最佳論文獎、大連理工大學優秀博士論文單項獎、錢令希力學獎等獎勵及榮譽十餘項。
代表性論文(Selected Papers):
[1] Yang Lu, Yue Ming, Liu Yuanchang, Guo Lie. RBFNN based Terminal Sliding Mode Adaptive Control for Electric Ground Vehicles after Tire Blowout on Expressway [J]. Applied Soft Computing, 2020, 92(7): 106304.
[2] Yang Lu, Yue Ming, Wang Jie, Hou Wenbin. RMPC-Based Directional Stability Control for Electric Vehicles Subject to Tire Blowout on Curved Expressway[J]. Journal of Dynamic Systems, Measurement, and Control, 2019, 141(4): 041009.
[3] Yang Lu, Yue Ming, Ma Teng. Path Following Predictive Control for Autonomous Vehicles Subject to Uncertain Tire-ground Adhesion and Varied Road Curvature[J]. International Journal of Control, Automation and Systems, 2019, 17(1): 193-202.
[4] Yang Lu, Yue Ming, Tian Haoyu, Yao Baozhen. Tire Blow-out Control for Direct Drive Electric Vehicles using Reconfiguration of Torque Distribution and Vertical Load [J]. Transactions of the Institute of Measurement and Control, 2020, 42(8): 1547-1558.
[5] Yang Lu, Liu Ke, Huang Heye, Liu Qiaobin, Gao Ming, Wang Jianqiang. Driver-automation collaboration steering control for intelligent vehicles under unexpected emergency conditions. 33rd IEEE Intelligent Vehicles Symposium, Aachen, Germany, Jun 5-9, 2022: 1623-1630.
[6] Yang Lu, Liu Qiaobin, Liu Ke, Gao Ming, Wang Jianqiang. Lateral motion risk assessment of autonomous vehicles under unexpected extreme condition. 15th International Symposium on Advanced Vehicle Control. Kanagawa, Japan, Sep 12-16, 2022: 1-5.
[7] Liu Qiaobin, Yang Lu, Wang Jianqiang, Li Keqiang. Vehicle type-dependent heterogeneous car-following modeling and road capacity analysis[J]. Modern Physics Letters B, 2022, online.
[8] Liu Qiaobin, Yang Lu, Gao Ming, Gao Bolin, Wang Jianqiang, Li Keqiang. Objective evaluation index for the comprehensive performance of intelligent vehicle lane-changing trajectory[J]. Proceedings of the Institution of Mechanical Engineers, Part D: Journal of Automobile Engineering, 2023, accepted.
[9] Yue Ming, Yang Lu, Sun Xi-Ming, Xia Weiguo. Stability Control for FWID-EVs With Supervision Mechanism in Critical Cornering Situations[J]. IEEE Transactions on Vehicular Technology, 2018, 67(11): 10387-10397.
[10] Yue Ming, Yang Lu, Zhang Hongzhi, Xu Gang. Automated Hazard Escaping Trajectory Planning/Tracking Control Framework for Vehicles Subject to Tire Blowout on Expressway[J]. Nonlinear Dynamics, 2019, 98(1): 61-74.
[11] 劉巧斌,楊路,高博麟,王建強,李克強. 基於認知風險動態平衡的智慧型汽車跟車模型[J]. 汽車工程,2022, 44(11), 1627-1635.
授權發明專利:
[1] 極限工況下車輛失穩與碰撞綜合風險評估方法及裝置, ZL202110934200.4, 2021
[2] 極限工況下人-車-路閉環系統動力學建模方法及系統. ZL202210082803.0, 2022
[3] 基於認知風險平衡的智慧型汽車跟車決策和控制方法. ZL202210045949.8, 2022
[4] 智慧型汽車換道時長預測及擬人化軌跡規劃方法. ZL202111237247.1, 2022
[5] 基於側向量化平衡指標的智慧型汽車擬人化軌跡規劃方法. ZL202111329587.7, 2022
[6] 自動駕駛車輛的擬人化軌跡規劃方法、裝置、車輛及介質. ZL202210657706.X, 2023
研究項目:
[1] 國家自然科學基金青年項目,緊急避障工況下智慧型汽車人機協同全向運動預測控制研究,2022.01~2024.12,主持
[2] 國家自然科學基金重大項目(課題),極限工況下人-車-路閉環系統動力學建模與失穩風險辨識,2018.01~2022.12,參與
所獲榮譽
[1] 第十八屆亞太智慧型交通論壇(18th ITS Asia Pacific Forum )最佳論文獎,2022
[2] 遼寧省優秀畢業博士研究生,2020
[3] 遼寧省自然科學學術成果獎,2019
[4] 大連理工大學優秀博士論文單項獎,2019
[5] 博士研究生國家獎學金,2019
[6] 第二十六屆錢令希力學獎,2019
社會任職
中國汽車工程學會青年工作委員會會員
中國自動化學會車輛控制與智慧型化專委會會員
第四屆中國車輛控制與智慧型化大會Vehicle Control Session Co-Chair
EI期刊World Electric Vehicle Journal專刊客座編輯
擔任IEEE TVT, IEEE T-ITS, IEEE RA-L, IET ITS, IJCAS等期刊審稿人
