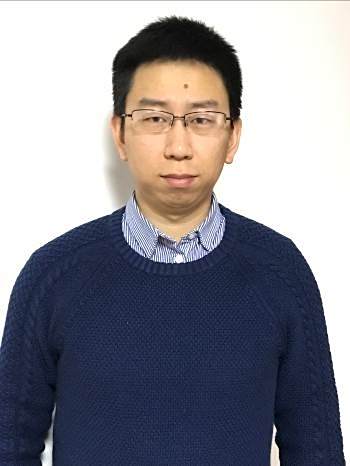
梁忠超,男,1984年出生,博士,東北大學機械工程與自動化學院教授、博士生導師,車輛工程研究所黨支部書記、副所長。
基本介紹
- 中文名:梁忠超
- 出生日期:1984年
- 畢業院校:哈爾濱工業大學
- 學位/學歷:博士
- 職業:教師
- 專業方向:工學
- 任職院校:東北大學
人物經歷,學習經歷,工作經歷,研究方向,講授課程,學術成果,科研項目,學術論文,
人物經歷
學習經歷
[1]2011.9至2015.1 哈爾濱工業大學,機電工程學院,工學博士
[2]2009.9至2011.8 哈爾濱工業大學,機電工程學院,工學碩士
[3]2003.9至2007.8 東北大學,機械工程與自動化學院,工學學士
工作經歷
[1]2024.01至今,東北大學,機械工程與自動化學院,教授/博士生導師
[2]2018.1至2023.12,東北大學,機械工程與自動化學院,副教授/碩士生導師(2021.01起 晉升為博士生導師)
[3]2015.3至2017.12東北大學,機械工程與自動化學院講師
研究方向
[1] 複雜系統的智慧型控制(生成式人工智慧,大數據模型,深度強化學習理論等)
[2] 多機器人/物流車的多任務分配策略研究(生成式人工智慧,機器學習等)
[3] 多機器人的協同搬運與協同感知研究(圖論,非線性系統理論,地面力學理論等)
[4] 無人駕駛車輛的智慧型駕駛控制與感知研究(非線性系統理論等)
[5] 空間科學與月面探測技術
講授課程
[1]《汽車製造工藝學》
[2]《電機驅動與控制》
學術成果
科研項目
代表性科研項目如下:
[1] 國家自然科學基金面上基金項目,基於多月球車系統的月壤力學特性分布理論與通過性區域劃分方法研究,2025.01~2028.12,國家級,主持。
[2] 國家自然科學基金面上基金項目,鬆軟複雜坡面地形條件下載人月球車運動與操縱特性的保持研究,2020/01~2023/12,國家級,主持。
[3] 國家自然科學基金青年基金項目,基於彈性篩網輪地面力學機理的載人月球車月面行駛模擬研究,2017/01~2019/12,國家級,主持。
學術論文
主要代表論文如下:
[1] Zhongchao Liang, Chunxiao Lyu, Mingyu Shen, Jing Zhao, Zhongguo Li, Zhengtao Ding. Distributed fixed-time control for leader-steered rigid shape formation with prescribed performance. IEEE Transactions on Cybernetics, 2024, DOI: 10.1109/TCYB.2024.3364146. (SCI, Q1, IF=11.8;中科院一區Top)
[2] Zhongchao Liang, Mingyu Shen, Zhongguo Li, Jun Yang. Model-free output feedback path following control for autonomous vehicle with prescribed performance independent of initial conditions. IEEE/ASME Transactions on Mechatronics, 2024, 29(2): 1076-1087. (SCI, Q1, IF=6.4;中科院一區Top)
[3] Zhongchao Liang, Mingyu Shen, Jing Zhao, Zhongguo Li, Yongfu Wang, Zhengtao Ding. Adaptive sliding mode fault tolerant control for autonomous vehicle with unknown actuator parameters and saturated tire force based on the center of percussion. IEEE Transactions on Intelligent Transportation Systems, 2023, 24(11): 11595-11606. (SCI, Q1, IF=8.5;中科院一區Top)
[4] Zhongchao Liang, Zhongnan Wang, Jing Zhao, Pak Kin Wong, Zhixin Yang, and Zhengtao Ding. Fixed-time prescribed performance path-following control for autonomous vehicle with complete unknown parameters. IEEE Transactions on Industrial Electronics, 2023, 70(8): 8426-8436. (SCI, Q1, IF=7.7;中科院一區Top)
[5] Zhongchao Liang, Zhongnan Wang, Jing Zhao, Pak Kin Wong, Zhixin Yang, and Zhengtao Ding. Fixed-time and fault-tolerant path following control for autonomous vehicles with unknown parameters subject to prescribed performance. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2023, 4(53): 2363-2373. (SCI, Q1, IF=8.7;中科院一區Top)
[6] Zhongchao Liang, Zhongnan Wang, Zhao Jing, and Xiaoguang Ma. Fast finite-time path following control for autonomous vehicle via complete model-free approach, IEEE Transactions on Industrial Informatics, 2023, 19(3): 2836-2846. (SCI, Q1, IF=12.3;中科院一區Top)
[7] Zhongchao Liang, Jing Zhao, Bo Liu, Yongfu Wang, and Zhengtao Ding. Velocity-based path following control for autonomous vehicles to avoid exceeding road friction limits using sliding mode method, IEEE Transactions on Intelligent Transportation Systems, 2022, 22(3): 1947-1958. (SCI, Q1, IF=8.5;中科院一區Top, ESI高被引)
[8] Zhongchao Liang, Jing Zhao, Zhen Dong, Yongfu Wang, and Zhengtao Ding. Torque vectoring and rear-wheel-steering control for vehicle's uncertain slips on soft and slope terrain using sliding mode algorithm. IEEE Transactions on Vehicular Technology, 2020, 69(4): 3805-3815. (SCI, Q1, IF=5.978;中科院二區Top)
[9] Zhongchao Liang, Jie Chen, Yongfu Wang. Equivalent acceleration imitation for single wheel of manned lunar rover by varying torque on earth. IEEE/ASME Transactions on Mechatronics, 2020, 25(1): 282-293. (SCI, Q1, IF=5.303;中科院一區Top)
[10] Zhongchao Liang, Jie Chen, Yongfu Wang, Liang Ding, Haibo Gao, Zongquan Deng. Approach for imitation of manned lunar rover acceleration using prototype vehicle with imitation handling ratio on Earth. IEEE Transactions on Vehicular Technology, 2018, 67(7): 5683-5694. (SCI, Q1, IF=5.339;中科院二區Top)
