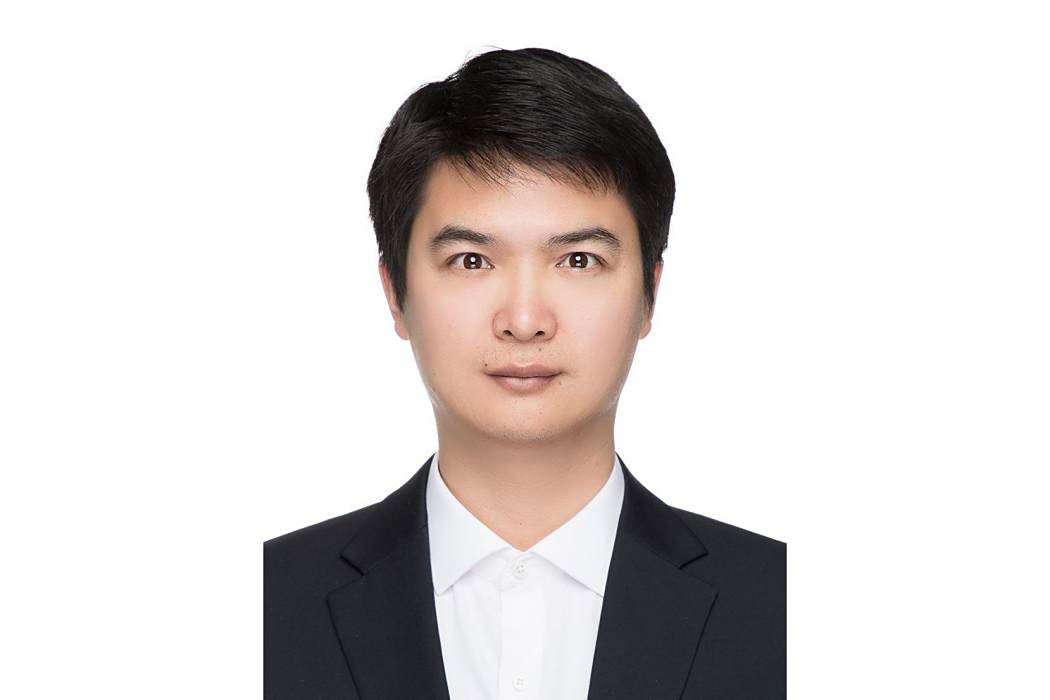
李國濤,中國科學院自動化研究所多模態人工智慧系統全國重點實驗室副研究員,主要研究方向為醫療康復機器人及手術機器人技術。2020年8月起先後任該所博士後、助理研究員及副研究員,主持國家自然科學基金面上項目、青年科學基金及北京市自然科學基金聯合項目等課題,聚焦外骨骼機器人感知控制、柔性驅動及康複評估等研究領域。
其研究成果包括開發自適應拇指外骨骼、自對準膝關節外骨骼系統,提出柔性手指力感知與多接觸互動控制方法,相關論文發表於《IEEE Transactions on Robotics》《Mechanism and Machine Theory》等期刊。獲IEEE ROBIO 2023最佳學生論文獎、RCAR 2021最佳論文獎等榮譽,並擁有多項發明專利,涵蓋腕手外骨骼力位感知裝置、錐形連續體柔性手術器械等核心技術。
研究方向,工作經歷,科研項目,代表性論著,獲獎及榮譽,發明專利,
研究方向
醫療康復機器人、手術機器人
工作經歷
2024.9-至今 中國科學院自動化研究所 副研究員
2022.6-2024.8 中國科學院自動化研究所 助理研究員
2020.8-2022.5 中國科學院自動化研究所 博士後
科研項目
1. 人機相容腕手外骨骼的正交力矩融合感知與主動柔順協同互動控制研究,國家自然科學基金面上項目,項目負責人,2025.01-2028.12
2. 多構態共融手部康復外骨骼機器人的運動相容最佳化設計與控制方法研究,國家自然科學基金青年科學基金項目,項目負責人,2022.01-2024.12
3. 基於新型可穿戴外骨骼的創傷患者腕手運動功能康復智慧型評估研究,北京市自然科學基金-海淀原始創新聯合基金,項目負責人,2023.1至2025.12
4. 仿肌腱驅動的柔性機器人關鍵技術研究,國家自然科學基金聯合基金項目,課題負責人,2023.1-2026.12
5. 連續體機器人靈巧精準軌跡規劃和智慧型柔順控制方法研究,國家自然科學基金委員會面上項目,課題負責人,2024.1-2027.12
代表性論著
1. Guotao Li, Long Cheng, Ziwen Gao, Xiuze Xia and Jingang Jiang, “Development of an untethered adaptive thumb exoskeleton for delicate rehabilitation assistance,” IEEE Transactions on Robotics, vol. 38, no. 6, pp. 3514-3529, 2022.
2. Guotao Li, Xu Liang, Huijuan Lu, Tingting Su, Zeng-Guang Hou, “Development and Validation of a Self-Aligning Knee Exoskeleton with Hip Rotation Capability,” IEEE Transactions on Neural Systems and Rehabilitation Engineering, vol. 32, pp. 472-481, 2024.
3. Guotao Li, Long Cheng, Can Zhang, “Design and Modeling of a Bioinspired Flexible Finger Exoskeleton for Strength Augmentation,” IEEE/ASME Transactions on Mechatronics, doi: 10.1109/TMECH.2024.3375873, 2024.
4. Guotao Li, Can Zhang, Can Su, Zhijie Liu, Xu Liang, Long Cheng, Zeng-Guang Hou, “Multicontact Intrinsic Force Sensing Method of a Flexible Finger for Hand Assistance,” IEEE Transactions on Instrumentation and Measurement, vol. 73, pp. 1-12, Art no. 4006512, 2024.
5. Guotao Li, Xu Liang, Yifan Gao, Tingting Su, Zhijie Liu, and Zeng-Guang Hou, “A linkage-driven underactuated robotic hand for adaptive grasping and in-hand manipulation,” IEEE Transactions on Automation Science and Engineering, vol. 21, no. 3, pp. 3039-3051, July 2024.
6. Jingang Jiang, Ziwen Gao, and Guotao Li (通訊作者), “A miniature elastic torque sensor for index finger exoskeletons,” IEEE Transactions on Instrumentation and Measurement, vol. 72, , Art no. 9507210, 2023.
7. Ning Sun, Guotao Li, and Long Cheng, “Design and validation of a self-aligning index finger exoskeleton for post-stroke rehabilitation,” IEEE Transactions on Neural Systems and Rehabilitation Engineering, vol. 29, pp. 1513-1523, 2021.
8. Guotao Li, Long Cheng, Ning Sun, “Design, Manipulability Analysis and Optimization of an Index Finger Exoskeleton for Stroke Rehabilitation,” Mechanism and Machine Theory, 2022, 167: 104526.
9. Guotao Li, Peng Xu, Shangling Qiao, Bing Li, “Stability analysis and optimal enveloping grasp planning of a deployable robotic hand,” Mechanism and Machine Theory, 2021, 158(2021):104241.
10. Guotao Li, Hailin Huang, Hongwei Guo, et al. “Design, analysis and control of a novel deployable grasping manipulator,” Mechanism and machine Theory, 2019, 138: 182-204.
獲獎及榮譽
中國科學院特別研究助理資助項目支持人選
Best Student Paper Award, IEEE ROBIO 2023國際會議
Best Paper Award, IEEE RCAR 2021國際會議
Best Paper Award, IEEE ICIST 2014國際會議
Best Paper Finalist, IEEE ICIA 2014國際會議
發明專利
1. 李國濤, 高子文, 楊閎竣, 姜金剛, 孫太任. 面向二自由度肢體關節的力位感知裝置及機器人. 中國: ZL202111513782.5.
2. 李國濤, 高子文, 楊閎竣, 孫太任, 梁旭, 姜金剛. 面向二自由度肢體關節的力位感知方法及系統. 中國: ZL 202111513781.0.
3. 李國濤, 劉市祺, 侯增廣, 婁倩文. 一種基於錐形連續體的四自由度柔性手術器械. 中國: ZL202311011067.0.
4. 李國濤, 劉市祺, 侯增廣, 婁倩文. 一種基於錐形連續體的七自由度柔性手術器械. 中國: ZL202311011090.X.
5. 李國濤, 梁旭, 盧慧娟, 侯增廣, 蘇婷婷. 一種二自由度運動輔助的膝關節外骨骼機器人. 中國: ZL202311829382.4.
