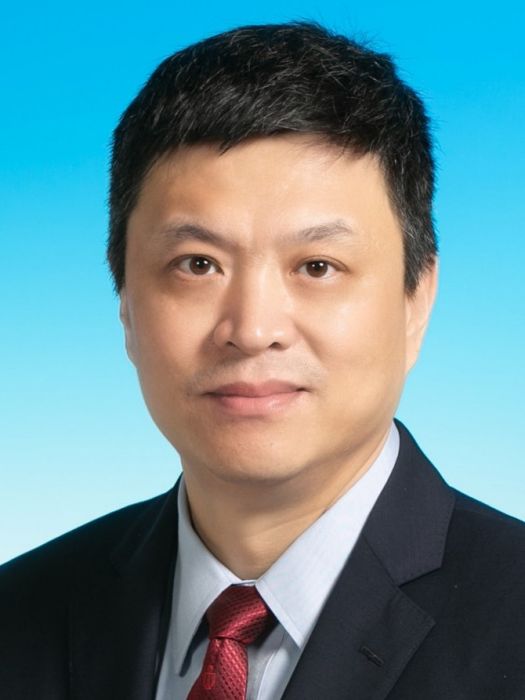
基本介紹
- 中文名:
- 畢業院校:
研究領域,人物介紹,人物經歷,獲得榮譽,代表作品,
研究領域
人物介紹
人物經歷
獲得榮譽
代表作品
[4] D. Chang, W. Wu, C. R.Edwards, and F. Zhang, “Motion Tomography: Mapping Flow Fields Using AutonomousUnderwater Vehicles,” International Journal of Robotics Research, 36(3):320-336, 2017. (31 citations/GS) IF 4.703
[5] N. Yao, E. Anaya, Q. Tao,S. Cho, H. Zheng and F. Zhang, “Monocular Vision-based Human Following on Miniature Robotic Blimp,” in Proc. 2017 IEEE International Conference on Robotics and Automation, 3244-3249, Singapore, 2017. (52 citations/GS)
[6] S. Zhang, J. Yu, A.Zhang, and F. Zhang, “Spiraling Motion of Underwater Gliders: Modeling,Analysis, and Experimental Results,” Ocean Engineering, 60: 1-13,2013. (180 citations/GS) IF 3.795
[7] W. Wu and F. Zhang,“Robust Cooperative Exploration with a Switching Strategy,” IEEETransactions on Robotics, 28(4), 828-839, 2012. (77 citations/GS) IF 5.567
[8] F. Zhang and N.E.Leonard, “Cooperative Control and Filtering for Cooperative Exploration,”IEEE Transactions on Automatic Control, 55(3):650-663, 2010. (288citations/GS) IF 5.792
[9] N. E. Leonard, D. A.Paley, R. E. Davis, D. M. Fratantoni, F. Lekien, and F. Zhang “Coordinated Control of an Underwater Glider Fleet in an AdaptiveOcean Sampling Field Experiment in Monterey Bay,” Journalof Field Robotics 27(6): 718-740, 2010. (341citations/GS) IF 3.767
[10] F. Zhang, D. M.Fratantoni, D. Paley, J. Lund and N.E. Leonard, “Control of CoordinatedPatterns for Ocean Sampling,” International Journal of Control 80(7):1186-1199, 2007. (201 citations/GS) IF 2.888
